Chengyuan Zhang
Understanding driving behavior through stochastic models and Bayesian inference.
I study why drivers behave differently in similar traffic situations, and how those differences shape traffic flow. My research develops stochastic car-following models and Bayesian inference methods to represent behavioral memory, driver heterogeneity, and latent driving regimes in naturalistic data.
I connect these models to uncertainty-aware traffic simulation, interpretable behavioral analysis, and reproducible model calibration.
I am a Postdoctoral Researcher in Civil Engineering at McGill University, working with Prof. Lijun Sun. I received my Ph.D. from the same group in 2026, and my B.Eng. in Vehicle Engineering from Chongqing University in 2019. I was also a visiting researcher at Carnegie Mellon University with Prof. Changliu Liu in 2023 and Prof. Ding Zhao in 2018, and at UC Berkeley with Prof. Masayoshi Tomizuka from 2019 to 2020.
Where I am heading. The methods above were developed on driving because it is one of the few human behaviors with both a mature mechanistic theory and enough measurement to test one. I now want to take the same approach to behavior that is harder to measure: interaction between people and automated vehicles, pedestrian movement, and world models with enough cognitive structure to say why someone acted rather than only what they did next. If you work on related problems, I would be glad to hear from you at enzozcy@gmail.com, or you can browse my CV.
Featured Research
Stochastic Behavior Models
How do memory, differences between drivers, and latent regimes organize driving variability?
Explore this research question
- Modeling Within-Driver Heterogeneity in Car-Following through Coupled Response–Scenario Dynamics (AI4T, accepted)
- When Context Is Not Enough: Modeling Unexplained Variability in Car-Following Behavior (ISTTT26 & TR Part B) [code]
- Calibrating Car-Following Models via Bayesian Dynamic Regression (ISTTT25 & TR Part C)
- A Bayesian Gaussian Mixture Model for Probabilistic Modeling of Car-Following Behaviors (IEEE T-ITS)
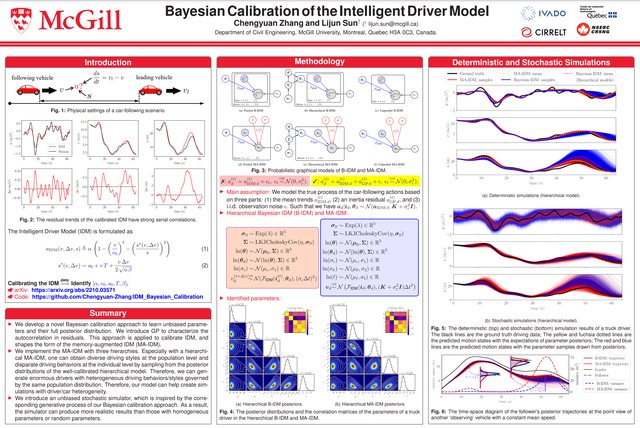
Scalable Bayesian Inference & Calibration
How can we infer behavior models from trajectories and express uncertainty in their parameters and predictions?
Explore this research question
- Active Simulation-Based Inference for Scalable Car-Following Model Calibration (arXiv: 2602.05246)
- Bayesian Calibration of the Intelligent Driver Model (IEEE T-ITS)
- AutoTune: A Unified Benchmark for Highway Traffic Microsimulation Calibration (IEEE IV 2026)
- Online Calibration of Context-Driven Car-Following Models (IEEE IV 2026)
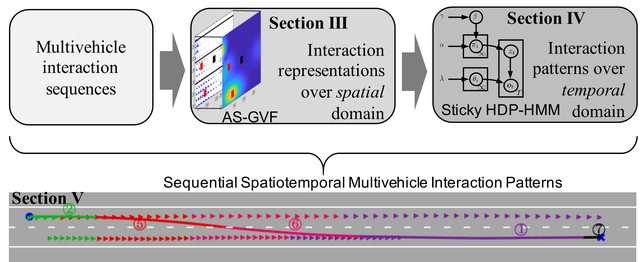
From Individual Behavior to Collective Dynamics
How do assumptions about individual driving variability enter collective traffic simulation?
Explore this research question
- From Micro Interactions to Traffic Flow: Stochastic Driver Models for Realistic Traffic Simulation (Ph.D. thesis, McGill 2026; one-page summary)
- Discovering dynamic patterns from spatiotemporal data with time-varying low-rank autoregression (IEEE TKDE)
- Forecasting sparse movement speed of urban road networks with nonstationary temporal matrix factorization (Transportation Science)
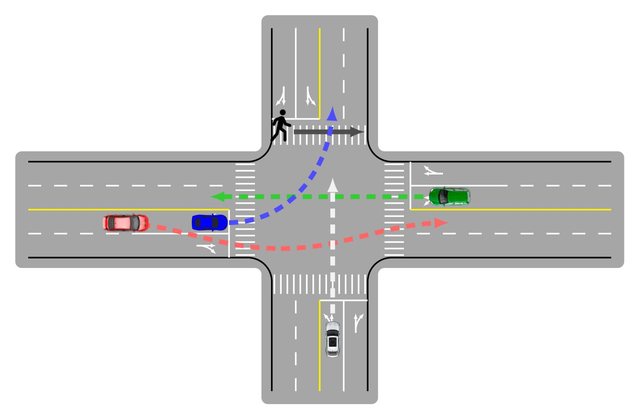
Multi-Agent Interaction
Representing how road users respond to one another, and when that response actually matters.
- Social interactions for autonomous driving: A review and perspectives (Foundations and Trends® in Robotics)
- Spatiotemporal learning of multivehicle interaction patterns in lane-change scenarios (IEEE T-ITS)
- Interactive Car-Following: Matters but NOT Always (IEEE ITSC23)
Selected Publications
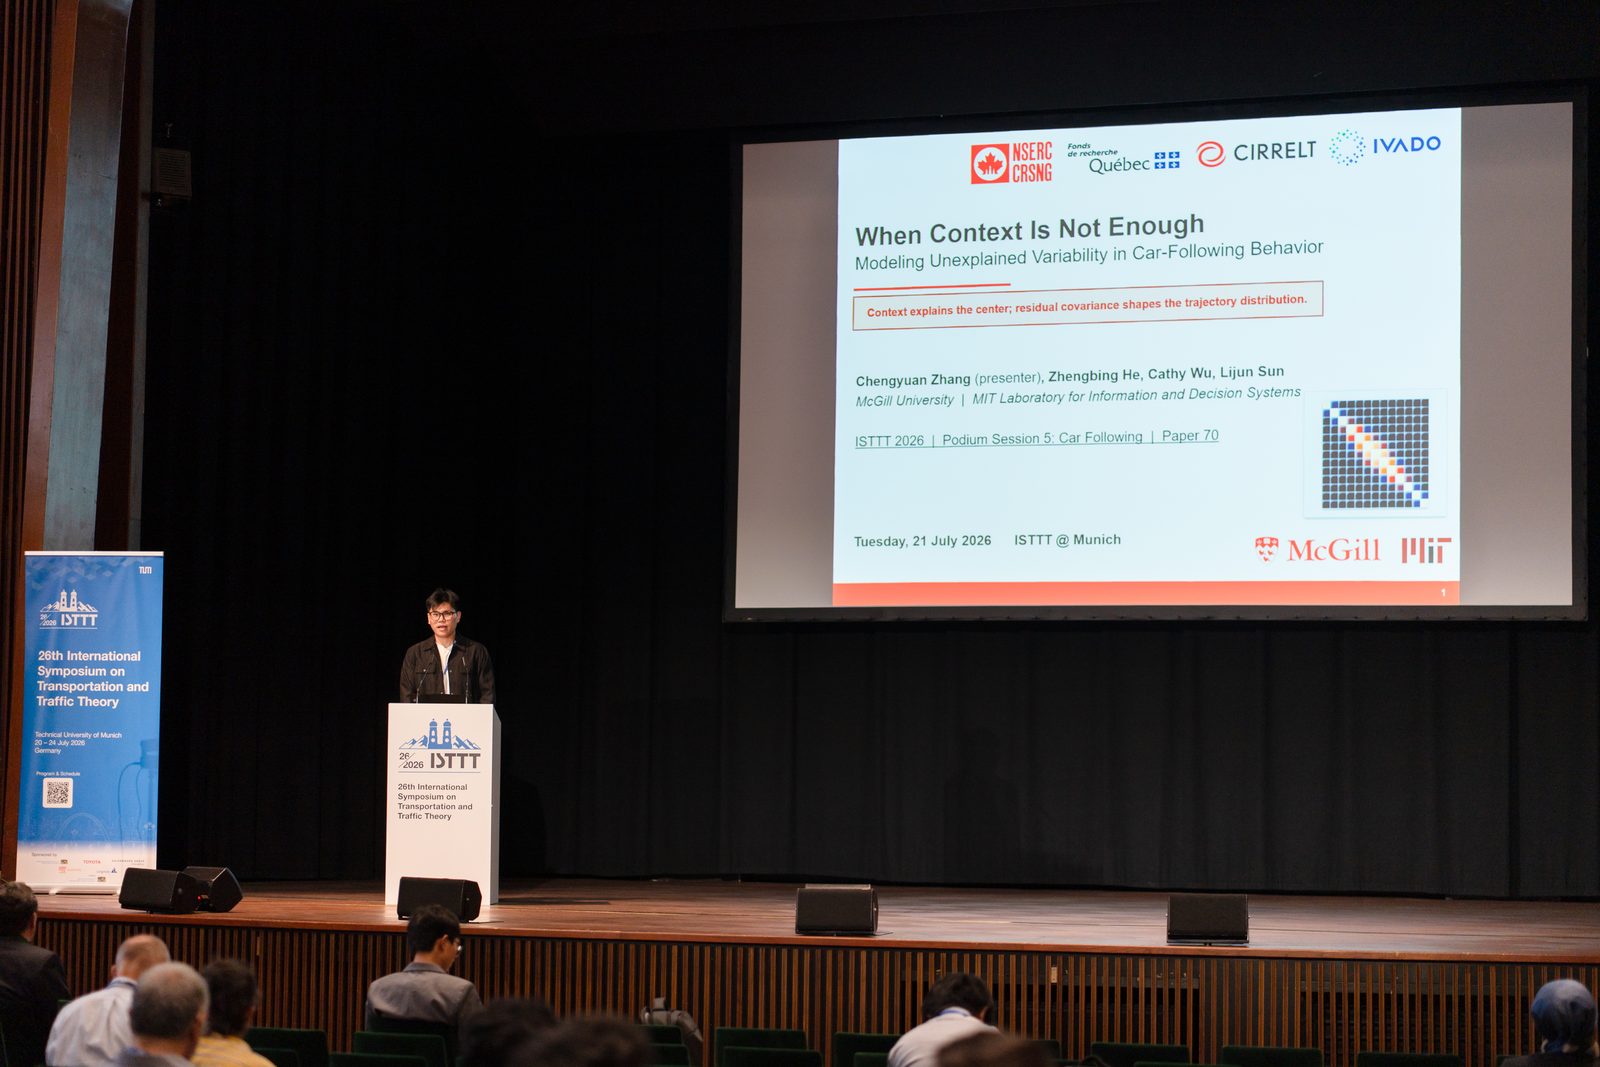
Combines context-dependent predictions with evolving residual covariance for stochastic car-following simulation.
research summary paper code poster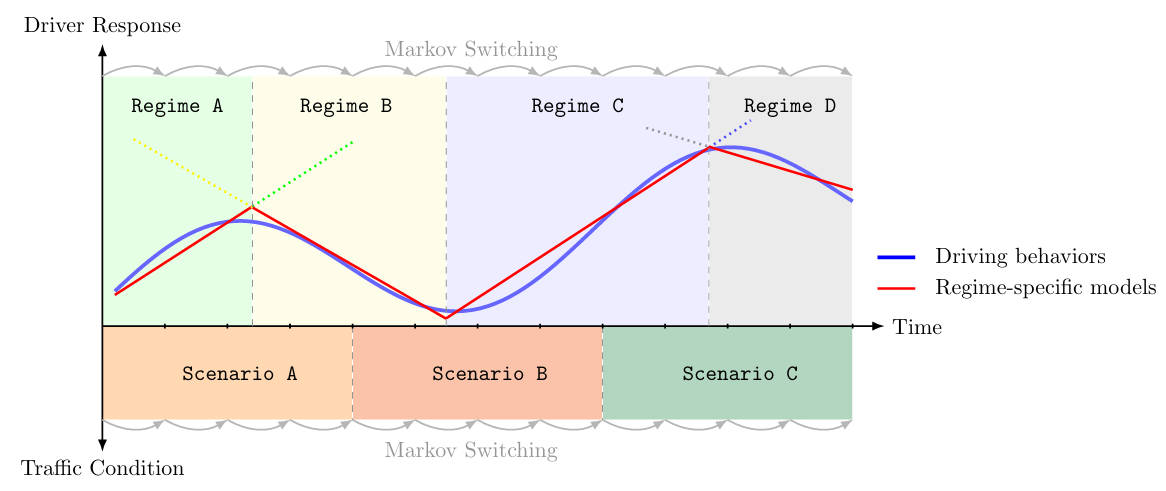
Models driving response regimes and traffic scenarios with a joint Markov process.
research summary earlier preprint (arXiv) earlier poster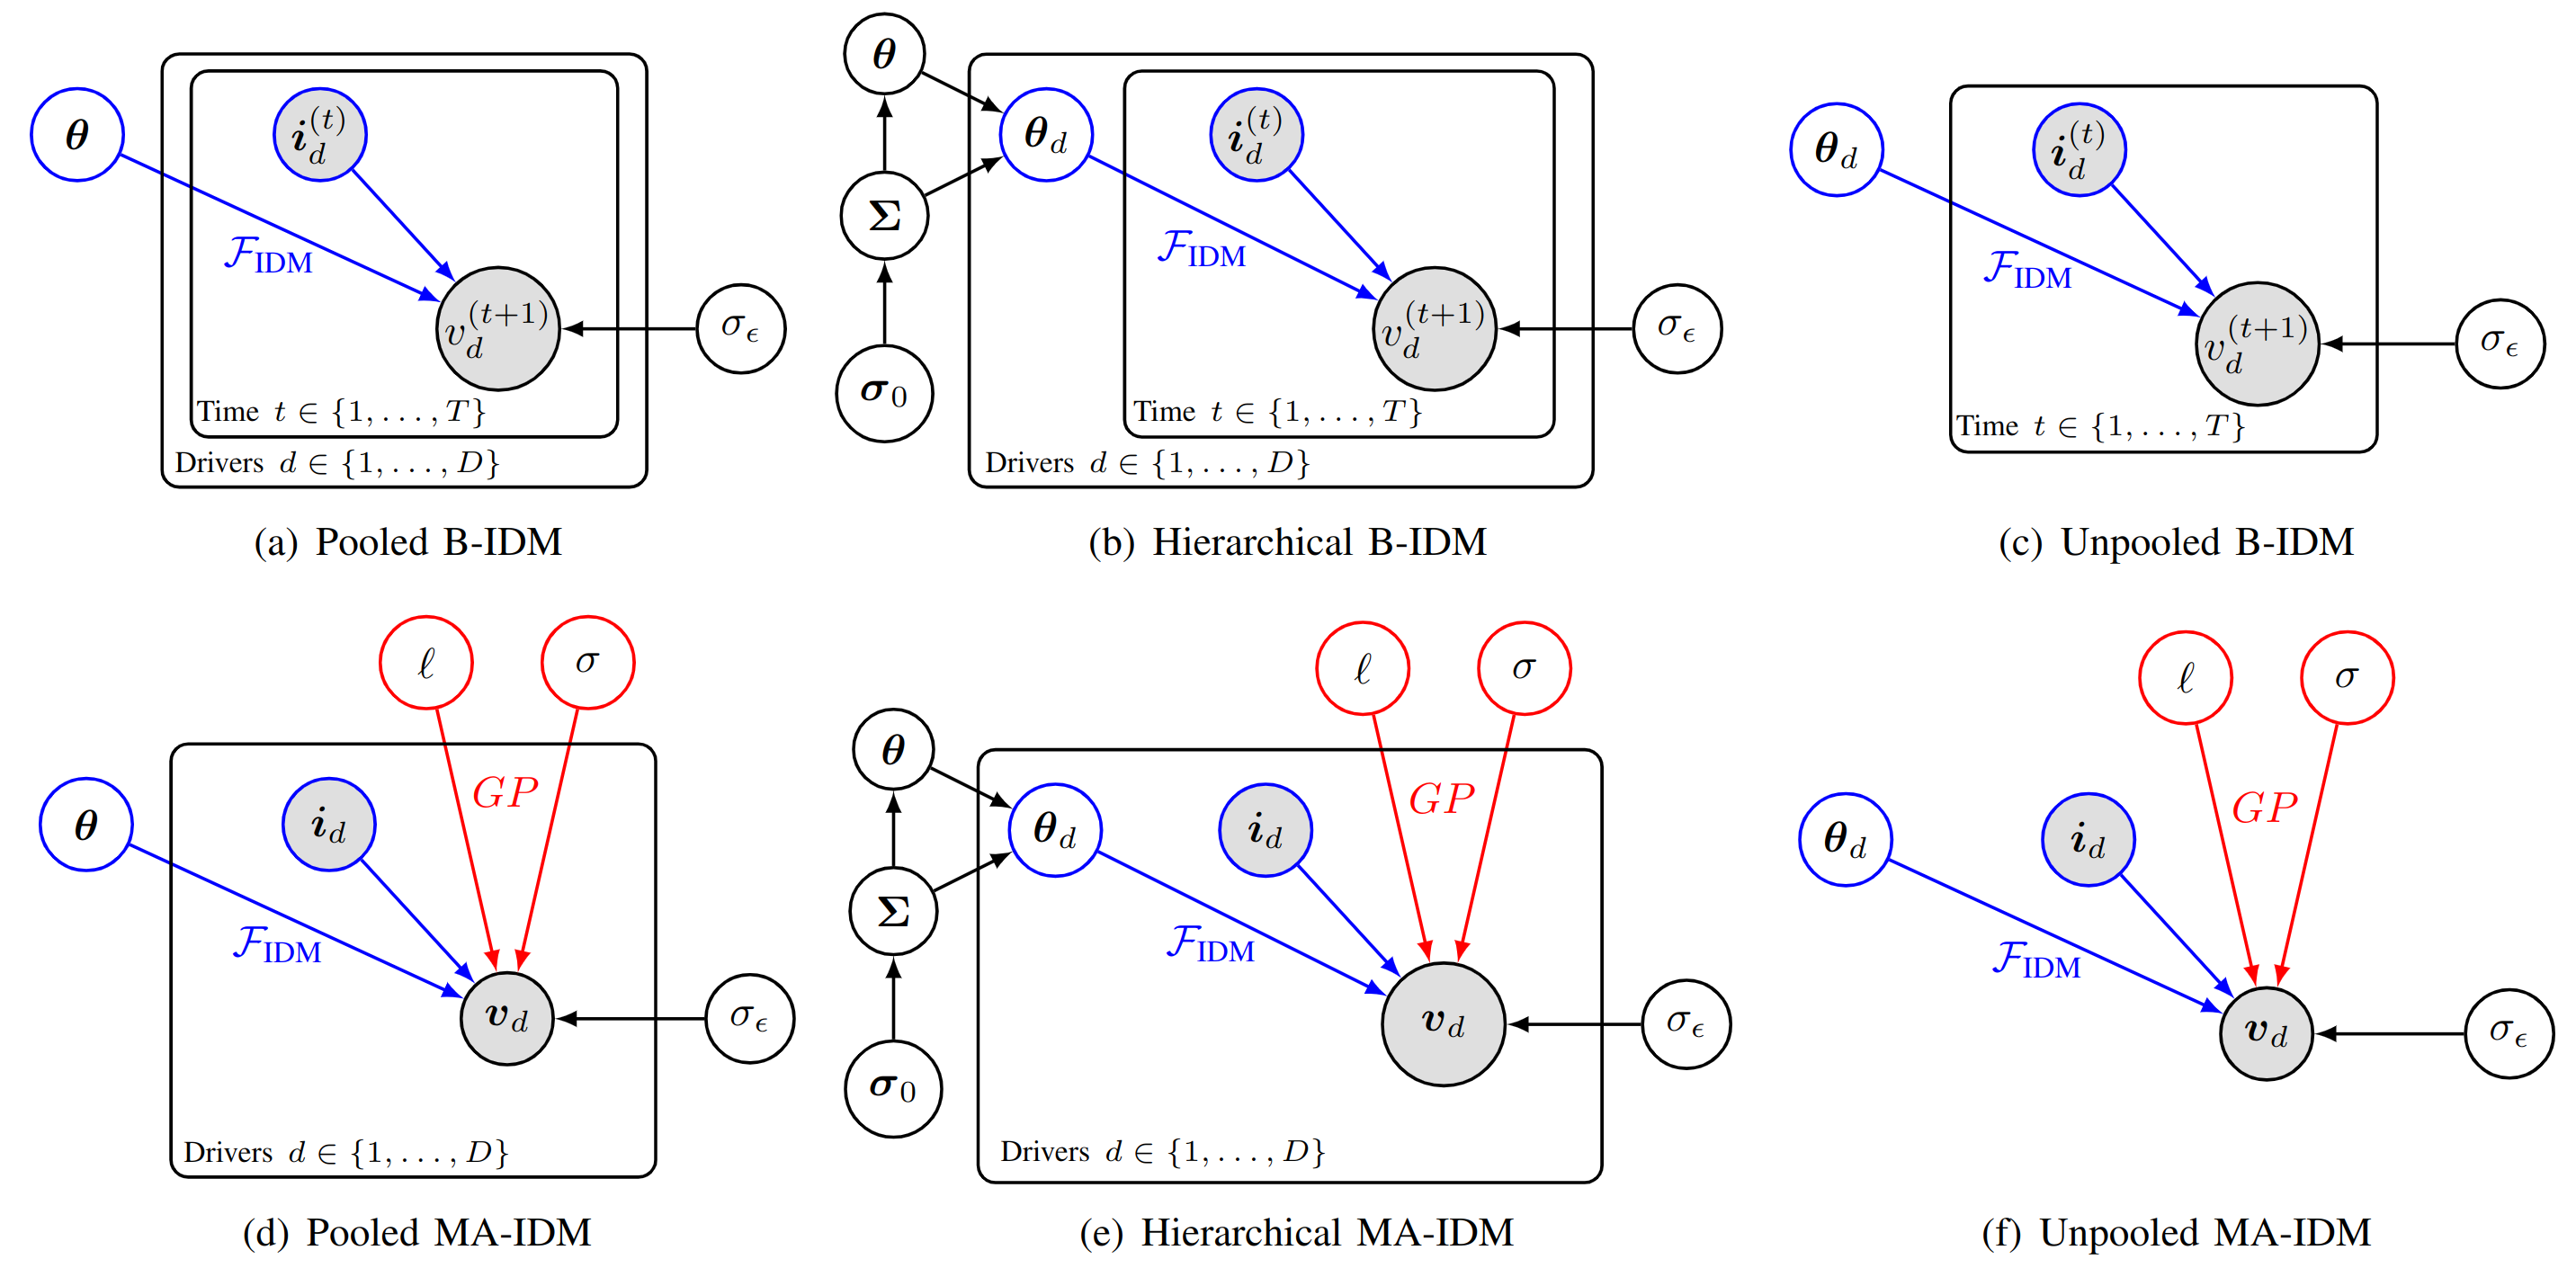
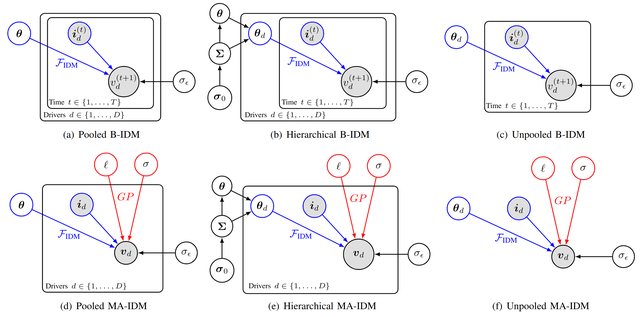
Combines hierarchical parameter uncertainty with temporally correlated residuals in memory-augmented IDM.
research summary paper code poster video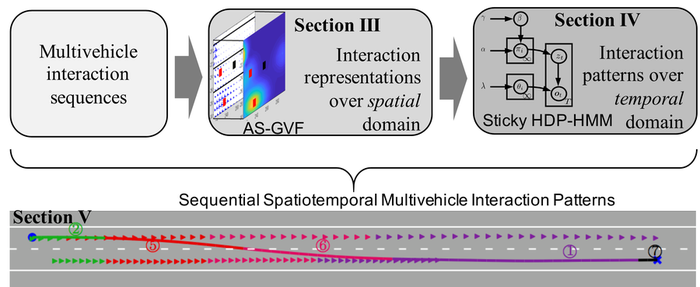
News
- 11/2026 “Modeling Within-Driver Heterogeneity in Car-Following through Coupled Response–Scenario Dynamics” accepted at Artificial Intelligence for Transportation (AI4T). [arXiv: 2506.14762]
- 07/2026 Talk at the Chair of Econometrics and Statistics, TU Dresden, hosted by Dr. Martin Treiber: “Beyond White Noise: What Naturalistic Data Reveal About Memory, Heterogeneity, and Latent Regimes in Car-Following.”
- 05/2026 Defended my Ph.D. thesis, From Micro Interactions to Traffic Flow: Stochastic Driver Models for Realistic Traffic Simulation, at McGill University. My thanks to my advisor Prof. Lijun Sun, to my committee, and to everyone who supported me along the way.